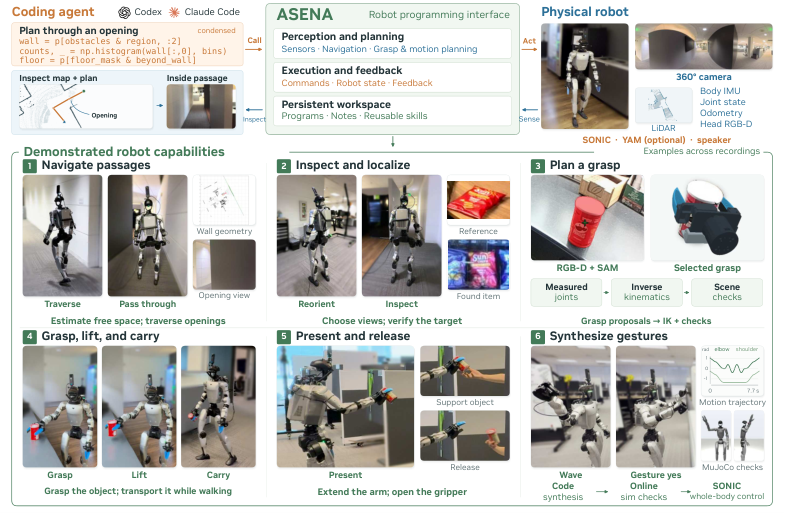
ASENA connects a coding agent to a robot’s sensors and movement controls. After trying a program, the agent can inspect the outcome, revise the routine, and save it for another task while its model weights stay fixed. The authors evaluated navigation in simulation and demonstrated search, visual inspection, and object transport on a Unitree G1 humanoid.
Figure 1 from the paper, by An-Chieh Cheng and coauthors, licensed under CC BY 4.0.