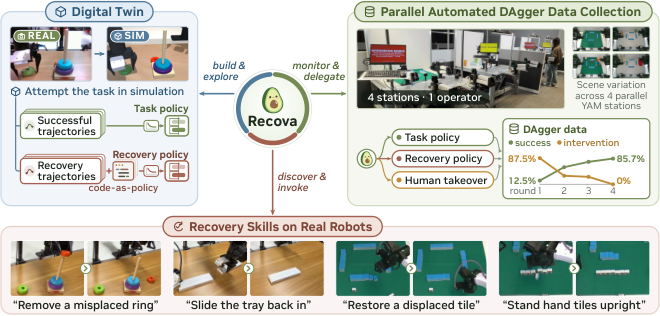
When a manipulation task fails, Recova tests ways to restore the scene in a digital twin. It learns separate policies for the task and for recovery, checks whether a correction worked on the physical robot, then resumes the original task. If the available skills cannot recover the scene, a human can demonstrate a correction for future attempts.
Figure 1 from the paper, by Isabella Liu and coauthors.