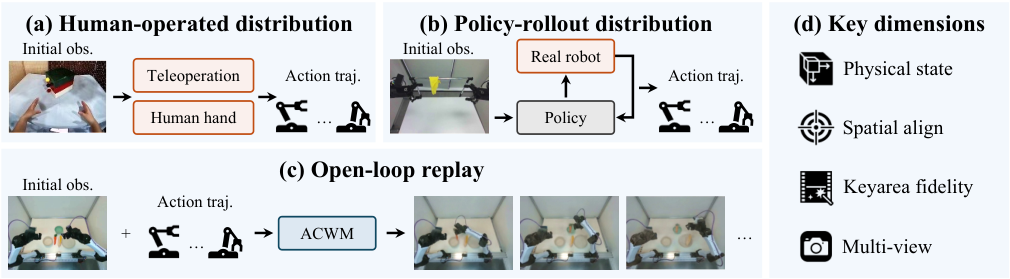
WorldOracle gives a model the starting observation and action sequence from a real robot trial, then compares its predicted video with the recording. The evaluation checks where contact happens, how objects change state, and whether the same interaction looks consistent across cameras. The recorded trials include successes and failures from human teleoperation and robot policies.
Figure 1 from the paper, by Haoyi Duan and coauthors.