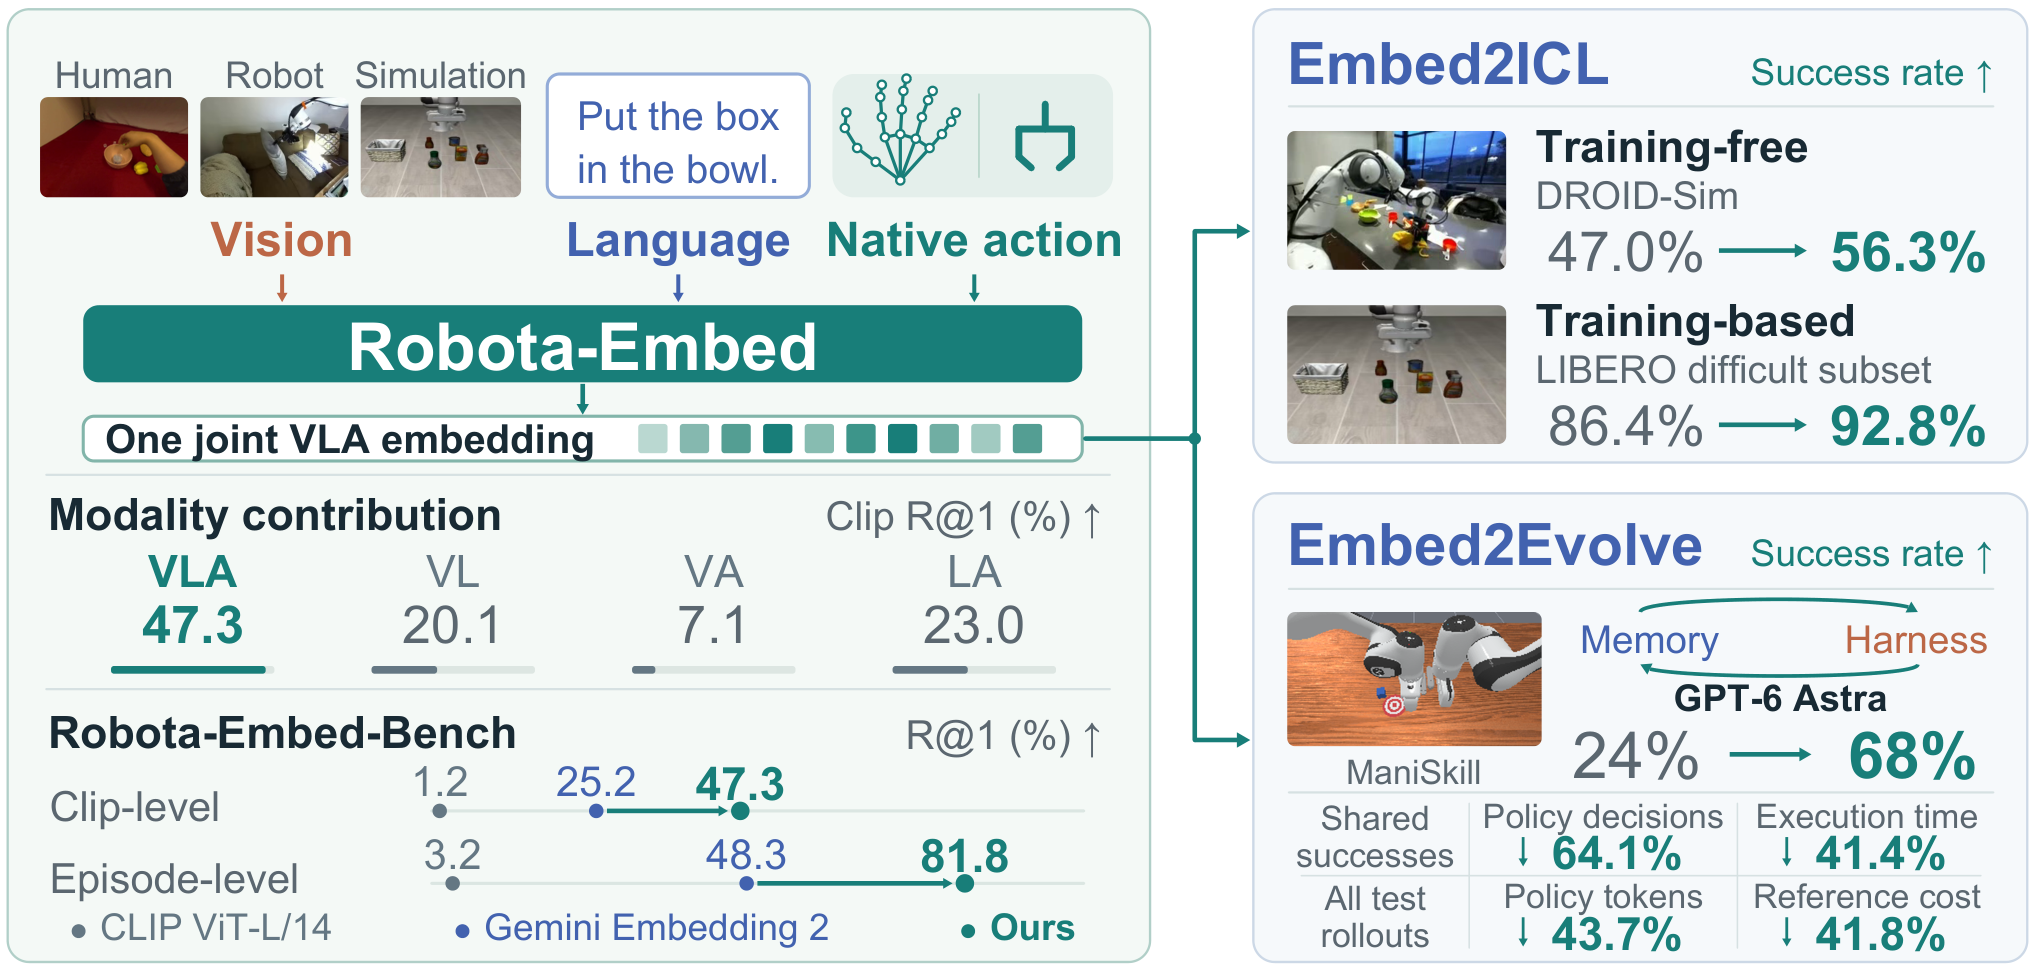
Robota-Embed matches a robot’s current task and actions to what happened next in a recorded demonstration. An action can distinguish two demonstrations that look alike but require different next steps. The authors use the retrieved examples to guide a policy and use execution feedback to improve the context available on later attempts.
Figure 1 from the paper, by Yunze Liu and coauthors.
* Equal contribution. † Corresponding author.