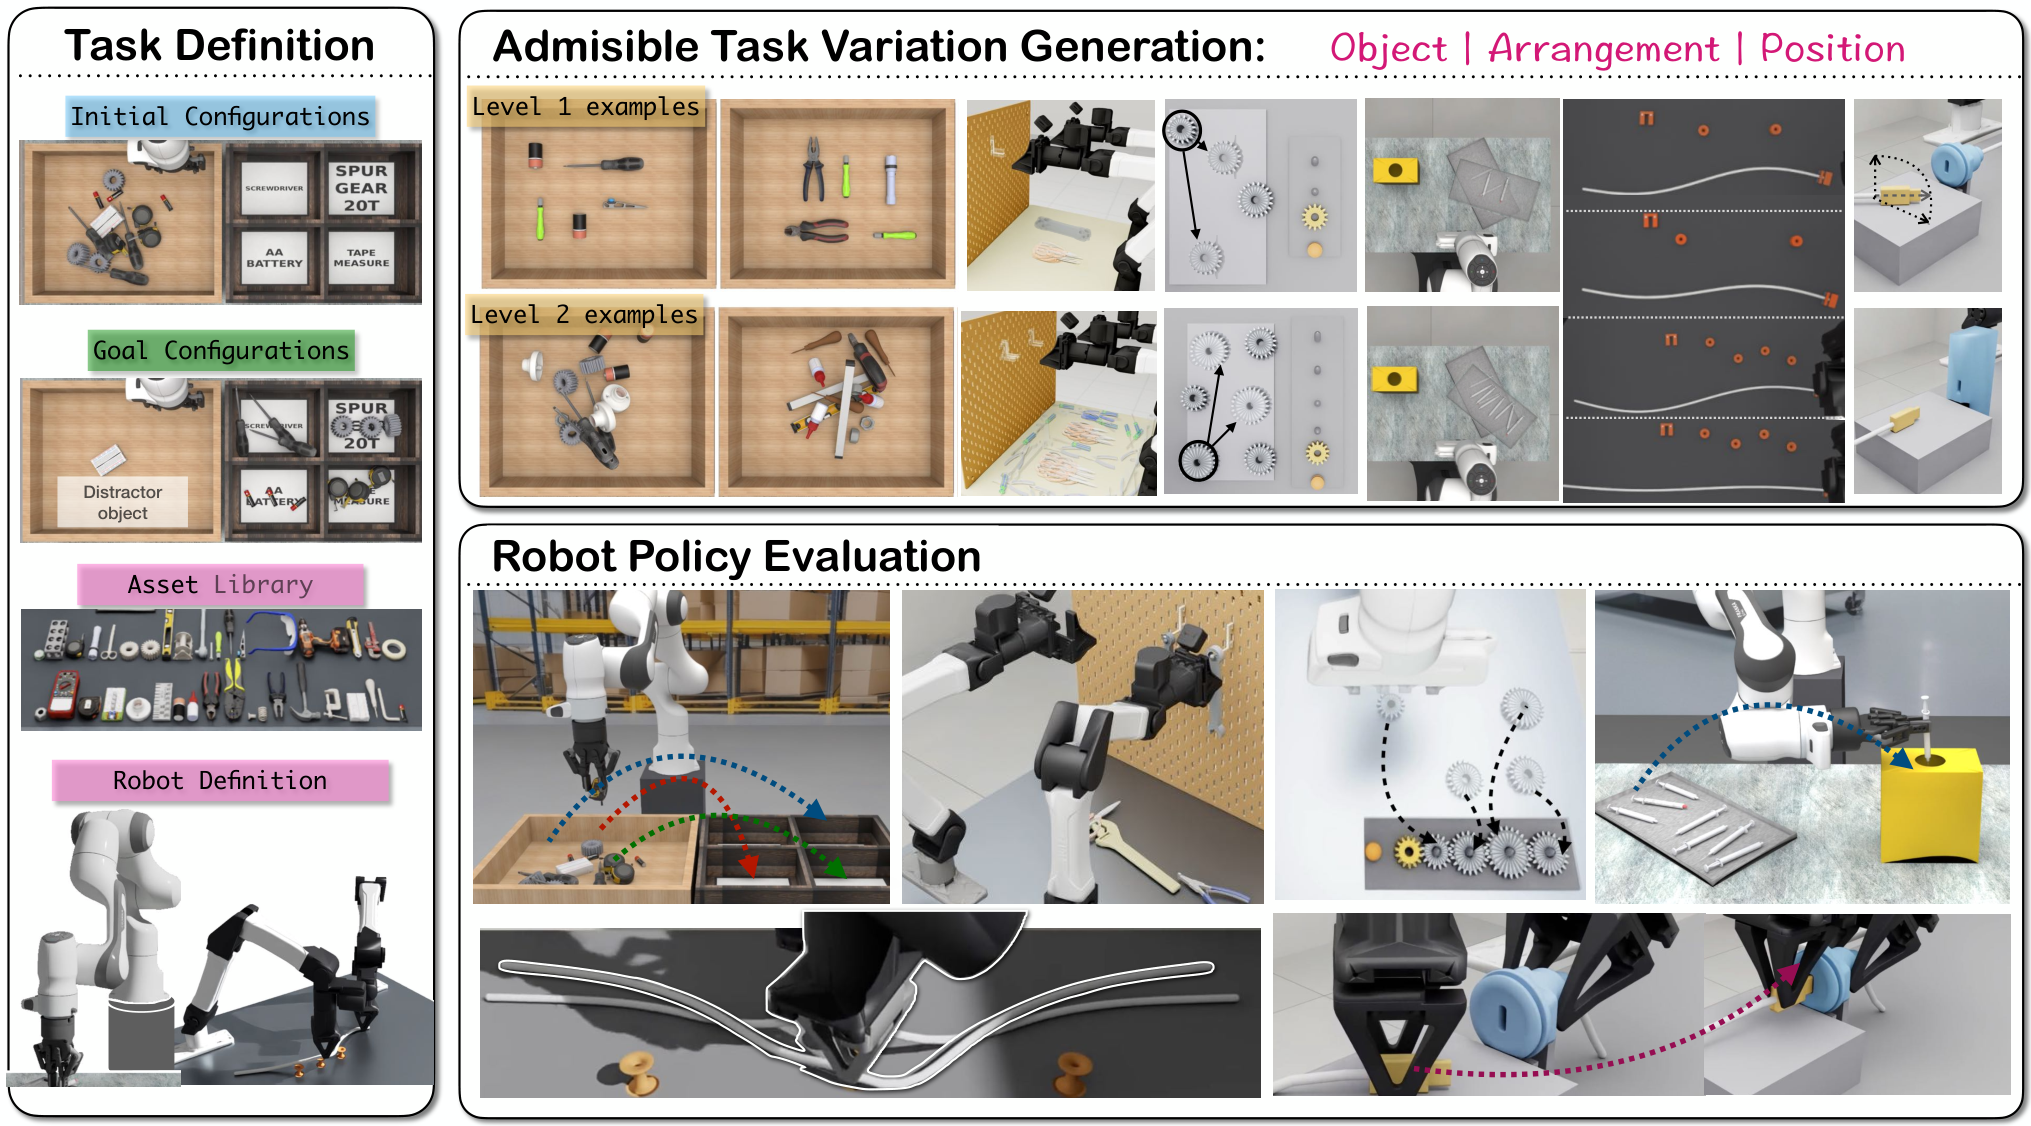
VABAR uses the Newton physics engine to vary the shapes and positions of objects in six manipulation tasks. The tasks include hanging tools, meshing gears, packing syringes, and routing cables. Each comes with repeatable difficulty settings and a success test. A library of 33 reusable robot skills provides building blocks for programmatic solutions and a common starting point for evaluating coding agents.
* Equal contribution.