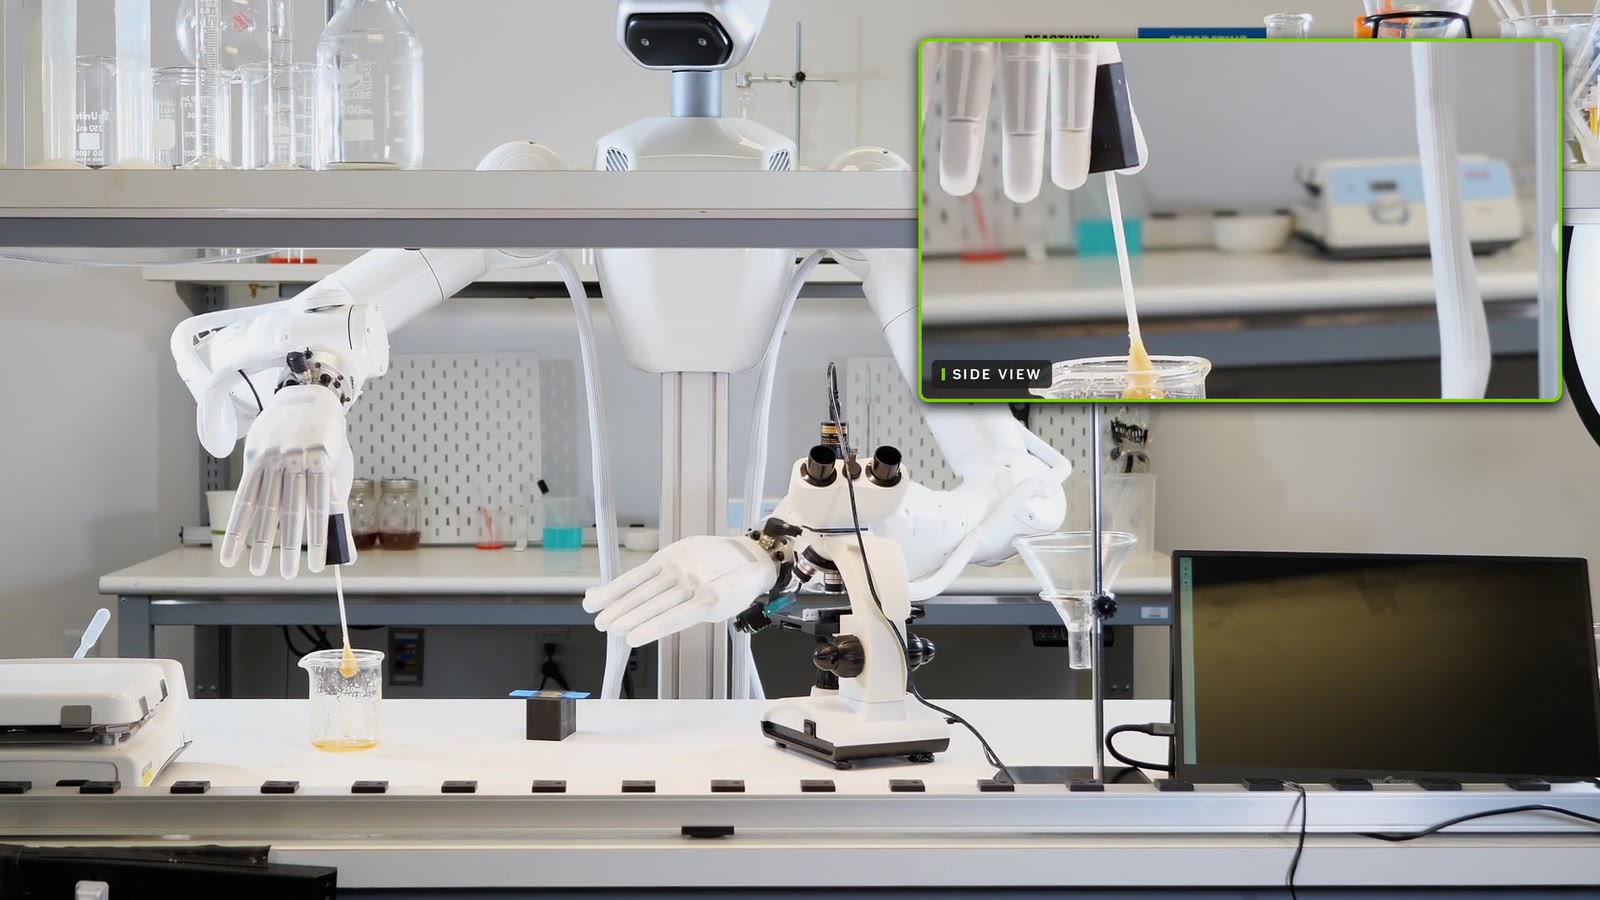
GR00T 2 predicts both the actions a robot should take and what its cameras will see as it moves. It learns from first-person human video, handheld gripper demonstrations, and teleoperated robots. The Turbo variant runs onboard a Unitree G1 humanoid and sends motion plans to SONIC. In one experiment, the humanoid holds a cup in one hand and scoops popcorn into it with the other.
Dexter-50 measures how well a two-handed robot can perform 50 tasks demonstrated by people or other robots during pretraining. GR00T 2 succeeded in 40% of trials before adaptation. Fine-tuning with five demonstrations per task from the target robot raised the success rate to 95%.